Robotics & Intelligent Motion
Biped and humanoid locomotion, robotic arms, robotic hands and mobile robot motion.
Research themes are grouped by practical relevance rather than presented as a static list of papers.
Each cluster links technical depth to applied outcomes.
Biped and humanoid locomotion, robotic arms, robotic hands and mobile robot motion.
Motion control, trajectory generation and tracking, precision positioning and system modelling.
Competency frameworks, curriculum, assessment and professional competency for tertiary TVET.
Engineering technology teaching, learning and student development.
Applied technology, digital adoption, Arduino and innovation practice.
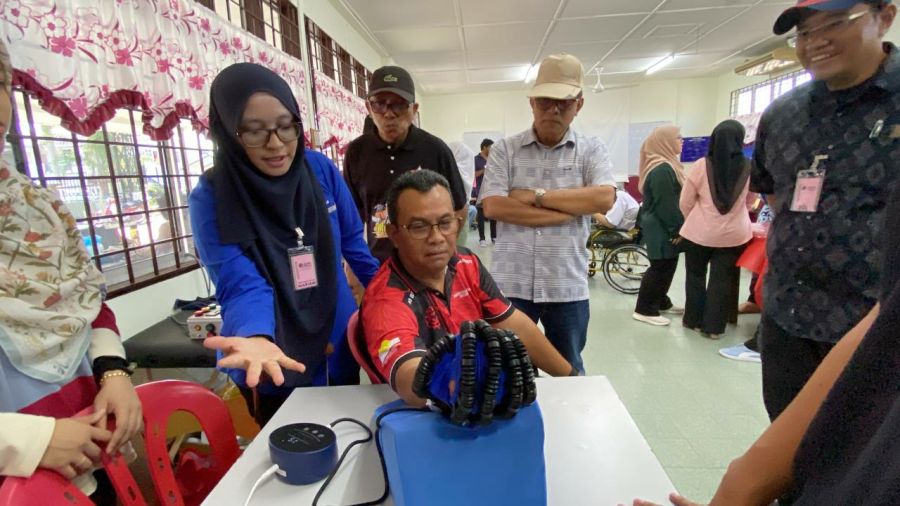
Rehabilitation and community technology, sustainability and STEM outreach.
Robotics, control, TVET, engineering education, innovation and sustainability.
Biped, humanoid, robotic arm and mobile robot systems.
Motion control, trajectory generation, tracking and system modelling.
Competency frameworks, curriculum and future-ready technical education.
Engineering technology teaching, learning and student development.
Applied technology, STEM, Arduino and digital innovation.
Technology for society, sustainability and community programmes.
Projects can be expanded over time through the CMS with source links and supporting media.
Research into trajectory generation and optimisation for effective biped robot locomotion.
Precision positioning and control strategies for robotic hand systems.
Trajectory tracking and control methodologies for mobile robot systems.
Tracking control of dual-limb robotic arm systems.
Contribution to competency frameworks supporting tertiary TVET educators.
Mentor-mentee STEM programme involving engineering, problem-solving, TRIZ and Arduino.
Community rehabilitation technology developed with a multidisciplinary UTeM team.
Applied technology for community and sustainability outcomes.